
Linux I2C & SPI Device Driver Development Guide
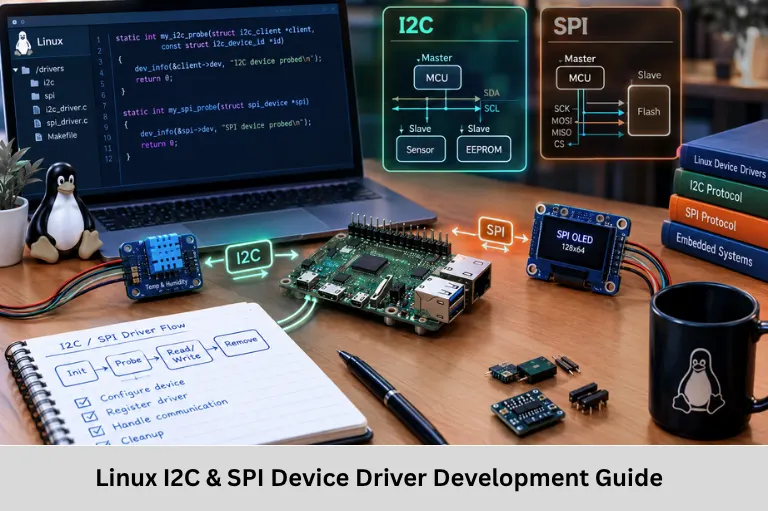
Learn Linux I2C and SPI device driver development, kernel frameworks, Device Tree, probe functions, data transfer APIs and embedded applications. Embedded Tech Development Academy (ETDA).
- Linux I2C & SPI Device Driver Development Guide
-
Linux I2C and SPI Device Driver Development in Embedded Linux Systems
- Introduction to Linux I2C and SPI Device Drivers
- Understanding Device Drivers in Embedded Linux
- I2C Communication in Embedded Linux
- Linux I2C Subsystem Architecture
- I2C Driver Data Transfer
- SPI Communication in Embedded Linux
- Linux SPI Subsystem
- Probe and Remove Functions
- Device Tree for I2C and SPI Devices
- I2C Versus SPI in Driver Development
- Debugging I2C and SPI Drivers
- Driver Development Best Practices
- Applications of I2C and SPI Device Drivers
- Frequently Asked Questions
- Conclusion
Linux I2C and SPI Device Driver Development in Embedded Linux Systems
Introduction to Linux I2C and SPI Device Drivers
Modern embedded systems rely on a wide range of external peripherals, including temperature sensors, accelerometers, EEPROMs, ADCs, DACs, display controllers, RTCs, touch controllers, flash memories, and wireless modules. These devices frequently communicate with processors through serial hardware interfaces such as I2C and SPI. In an Embedded Linux system, communication with these peripherals is not normally implemented by directly manipulating processor registers from application code. Instead, the Linux kernel provides structured bus frameworks and device-driver interfaces.
A Linux device driver acts as the software layer between hardware and the kernel. For I2C and SPI peripherals, the driver communicates through the corresponding kernel subsystem while the bus controller driver manages the underlying hardware controller. This layered design separates hardware control, bus management, device-specific logic, Device Tree configuration, and user-space interfaces.
Understanding Linux device drivers, I2C bus architecture, SPI communication, kernel APIs, probe and remove callbacks, Device Tree, device matching, register access, synchronization, error handling, and power management is therefore important for embedded engineers.
These concepts are especially relevant in Embedded Linux, where a processor may simultaneously communicate with multiple sensors, memory devices, displays, and communication modules. Embedded Tech Development Academy (ETDA) provides practical technical training in Linux, Embedded Linux, device drivers, communication protocols, and embedded systems. Learners looking for a Top Embedded Training Institute in Bangalore can develop these skills through hands-on technical learning with assured placement support.
Understanding Device Drivers in Embedded Linux
Role of a Linux Device Driver
A device driver enables the Linux kernel to control and communicate with a particular class of hardware.
Driver and Hardware Layers
A typical architecture can be represented as:
User Application
       |
       v
Device Interface / Kernel Subsystem
       |
       v
I2C or SPI Device Driver
       |
       v
I2C or SPI Core
       |
       v
Bus Controller Driver
       |
       v
Hardware Controller
       |
       v
Peripheral Device
Why Layering Matters
This architecture prevents every peripheral driver from having to implement controller-level register manipulation. The bus framework provides standardized APIs, while the device driver concentrates on device-specific registers, initialization, configuration, and data processing.
I2C Communication in Embedded Linux
I2C Bus Fundamentals
Inter-Integrated Circuit (I2C) is a synchronous two-wire serial communication protocol commonly used for relatively low-speed peripheral communication.
The two primary signals are:
- SDA – Serial Data
- SCL – Serial Clock
I2C devices normally have addresses, allowing multiple peripherals to share the same physical bus.
I2C Electrical Architecture
I2C lines are typically implemented using open-drain or open-collector signaling with pull-up resistors. The bus controller and devices actively pull the lines low while the pull-ups establish the high level.
Typical I2C Peripherals
I2C is commonly used with:
- Temperature sensors
- EEPROMs
- RTCs
- GPIO expanders
- Accelerometers
- Magnetometers
- Power-management ICs
- Touch controllers
Linux I2C Subsystem Architecture
I2C Adapter and Client
The Linux I2C framework separates the bus controller from the peripheral device.
An I2C adapter represents the controller capable of communicating over an I2C bus. An I2C client represents a peripheral device attached to that bus.
I2C Device Driver
The device-specific driver generally registers an i2c_driver structure containing information such as device matching information and callbacks.
A simplified structure is:
static struct i2c_driver sensor_driver = {
    .driver = {
        .name = "example_sensor",
    },
    .probe = sensor_probe,
    .remove = sensor_remove,
};
Device Matching
The kernel can match devices using mechanisms such as Device Tree compatible strings, ACPI information, or legacy I2C device-ID mechanisms, depending on the platform.
I2C Driver Data Transfer
Kernel I2C APIs
An I2C driver should normally use kernel I2C APIs rather than directly accessing controller registers.
Common APIs include:
i2c_smbus_read_byte_data();
i2c_smbus_write_byte_data();
i2c_master_send();
i2c_master_recv();
i2c_transfer();
Register-Based Devices
Many sensors expose internal registers.
A typical operation might be:
Write Register Address
        |
        v
Read Register Data
Error Handling
A production driver should check return values from every communication operation. Bus errors, missing devices, arbitration problems, invalid addresses, or hardware failures can cause transfers to fail.
SPI Communication in Embedded Linux
SPI Bus Signals
Serial Peripheral Interface (SPI) is a synchronous serial protocol designed for efficient full-duplex communication.
A typical SPI interface includes:
- MOSI – Master Out, Slave In
- MISO – Master In, Slave Out
- SCLK – Serial Clock
- CS – Chip Select
Unlike I2C addressing, SPI commonly selects peripherals through individual chip-select signals.
SPI Performance
SPI can provide substantially higher throughput than typical I2C configurations and is often selected for devices that transfer larger amounts of data.
Typical SPI Peripherals
Common examples include:
- ADCs
- DACs
- Display controllers
- NOR flash
- Wireless transceivers
- High-speed sensors
Linux SPI Subsystem
Linux SPI Subsystem
The Linux SPI subsystem separates the SPI controller from the peripheral device driver.
The SPI controller driver manages the processor’s SPI hardware, while an SPI device driver implements communication with a particular peripheral.
spi_driver Structure
A simplified driver can contain:
static struct spi_driver example_driver = {
    .driver = {
        .name = "example_spi",
    },
    .probe = example_probe,
    .remove = example_remove,
};
SPI Transfer Model
SPI transfers can be performed using kernel interfaces such as:
spi_sync();
spi_async();
spi_write();
spi_read();
For more complex transactions, spi_message and spi_transfer structures allow multiple transfer segments to be combined.
Probe and Remove Functions
Driver Probe
The probe callback is executed when the kernel successfully matches a driver with a device.
Typical Probe Operations
A probe function may:
- Allocate driver-private memory.
- Read Device Tree properties.
- Configure communication parameters.
- Initialize hardware registers.
- Register an application-facing interface.
- Enable required regulators or clocks.
- Configure interrupts.
Probe Failure Handling
If initialization fails, the driver should release resources already allocated before returning an error. Correct error unwinding is essential for stable Embedded Linux systems.
Remove Callback
The remove callback releases resources when the device or driver is removed.
It may undo:
- Memory allocation
- Interrupt registration
- GPIO configuration
- Runtime resources
- User interfaces
- Power-management resources
Device Tree for I2C and SPI Devices
Hardware Description
Modern embedded Linux platforms commonly use Device Tree to describe processor-connected hardware.
A simplified I2C node may look like:
&i2c1 {
    status = "okay";

    sensor@48 {
        compatible = "vendor,example-sensor";
        reg = <0x48>;
    };
};
SPI Device Description
A simplified SPI configuration can specify a chip-select:
&spi1 {
    status = "okay";

    flash@0 {
        compatible = "vendor,example-flash";
        reg = <0>;
        spi-max-frequency = <20000000>;
    };
};
Device Tree Matching
The compatible property allows the kernel to associate the hardware description with a suitable driver. Other properties can specify addresses, chip-select numbers, maximum SPI frequency, GPIOs, interrupts, regulators, and device-specific configuration.
I2C Versus SPI in Driver Development
Architectural Differences
I2C and SPI have different electrical and protocol characteristics.
Comparison
| Feature | I2C | SPI |
|---|---|---|
| Main signals | SDA, SCL | MOSI, MISO, SCLK, CS |
| Addressing | Device address | Chip select |
| Duplex | Typically half-duplex transactions | Full-duplex capable |
| Hardware complexity | Lower pin count | More signals |
| Typical speed | Lower | Higher |
| Common usage | Sensors, RTC, EEPROM | Flash, displays, ADCs |
Driver Selection
The peripheral’s electrical interface, bandwidth requirements, protocol characteristics, available processor pins, and system architecture determine whether I2C or SPI is appropriate.
Debugging I2C and SPI Drivers
Kernel Logs
dmesg and kernel logging functions such as dev_err() and dev_info() are useful for driver diagnostics.
dev_err(dev, "Sensor initialization failed\n");I2C Debugging
Engineers can inspect:
- Bus availability
- Device addresses
- Transfer errors
- ACK/NACK behavior
- Register values
- Timing configuration
SPI Debugging
SPI debugging may require checking:
- Chip-select behavior
- Clock polarity
- Clock phase
- Maximum frequency
- Transfer length
- Bit order
- MOSI/MISO signals
Oscilloscopes or logic analyzers can be particularly useful for verifying actual bus waveforms.
Driver Development Best Practices
Reliability Considerations
A production I2C or SPI driver should include:
- Proper resource management
- Robust error handling
- Correct synchronization
- Device Tree validation
- Appropriate timeout handling
- Power-management support
- Kernel logging
- Concurrency protection
Avoid Direct Hardware Access from User Space
Applications should generally communicate through an appropriate kernel interface rather than directly manipulating hardware registers.
Embedded Linux Maintainability
Using standard kernel frameworks makes drivers easier to maintain and port across processor families and embedded systems.
Applications of I2C and SPI Device Drivers
IoT and Sensor Systems
I2C is frequently used for environmental and motion sensors in Internet of Things (IoT) devices.
Industrial Automation
SPI and I2C peripherals can provide sensor measurements, ADC/DAC conversion, display control, and system monitoring.
Automotive Embedded Systems
Embedded Linux platforms may use serial peripherals for sensor interfaces, diagnostics, power management, and other hardware functions.
Data Acquisition
High-speed SPI peripherals can be useful when an application requires frequent sensor sampling or ADC data acquisition.
System Integration
The driver connects these hardware devices to the Linux software architecture, allowing higher-level applications and services to consume hardware data through standardized interfaces.
Frequently Asked Questions
What is an I2C device driver in Linux?
An I2C device driver is a kernel component that communicates with an I2C peripheral through the Linux I2C subsystem and implements the device-specific initialization, configuration, data transfer, and control logic.
What is an SPI device driver?
An SPI device driver is a kernel component that controls a specific SPI peripheral using the Linux SPI framework and SPI controller infrastructure.
What is the purpose of the probe function?
The probe function initializes a device after the kernel matches it with the appropriate driver. It commonly allocates resources, configures hardware, reads configuration, and registers required interfaces.
Why is Device Tree important for I2C and SPI?
Device Tree describes hardware configuration separately from driver source code. It can specify compatible strings, I2C addresses, SPI chip-selects, frequencies, GPIOs, interrupts, and other hardware properties.
Which is faster, I2C or SPI?
SPI generally supports higher transfer rates and efficient full-duplex communication, while I2C uses fewer signal lines and supports multiple addressed devices on a shared bus. The appropriate choice depends on the peripheral and system requirements.
Conclusion
Linux I2C and SPI device driver development is a core skill for engineers working with Embedded Linux and hardware-connected embedded systems. Sensors, EEPROMs, ADCs, DACs, displays, flash memories, wireless modules, and other peripherals depend on reliable communication between the processor and external hardware.
The Linux kernel simplifies this development through dedicated I2C and SPI subsystems. Instead of implementing complete bus-controller logic inside every peripheral driver, developers work with standardized kernel frameworks, device structures, transfer APIs, probe and remove callbacks, Device Tree descriptions, power-management interfaces, and resource-management mechanisms.
For I2C development, engineers need to understand concepts such as SDA, SCL, device addresses, I2C adapters, I2C clients, SMBus operations, i2c_transfer(), register-based communication, and bus errors. For SPI development, knowledge of MOSI, MISO, SCLK, chip select, SPI modes, clock frequency, spi_transfer, spi_message, and synchronous or asynchronous transfers is essential.
Device Tree adds another important layer by separating hardware configuration from driver implementation. Correct compatible strings, I2C addresses, SPI chip-select configuration, GPIO definitions, interrupts, clocks, regulators, and communication frequencies are critical for successful hardware initialization.
Embedded Tech Development Academy (ETDA) provides practical technical training in Linux, Embedded Linux, C/C++, kernel concepts, device drivers, communication protocols, and embedded systems. Learners searching for a Top Embedded Training Institute in Bangalore can strengthen their driver-development skills through hands-on technical learning with assured placement support.
For engineers developing embedded systems, driver development also requires careful attention to concurrency, error recovery, resource cleanup, power management, timing, and hardware debugging. A driver that works during a basic transfer is not necessarily production-ready; it must also handle communication failures, device removal, suspend/resume scenarios, invalid configuration, and long-term operation.
Embedded Tech Development Academy (ETDA) can help learners connect Linux kernel concepts with practical hardware interfacing and embedded systems development. A Top Embedded Training Institute in Bangalore approach that combines kernel programming, I2C, SPI, Device Tree, C programming, and hardware debugging can provide a structured technical foundation with assured placement support.
As Internet of Things (IoT) devices, industrial controllers, automotive platforms, robotics systems, and edge-computing products continue to use Linux-capable processors, knowledge of I2C and SPI driver development remains technically valuable. Embedded Tech Development Academy (ETDA) supports this learning path with practical training and assured placement support for learners building skills through a Top Embedded Training Institute in Bangalore environment.
Ultimately, I2C and SPI driver development is not simply about sending and receiving bytes. It requires understanding the Linux kernel’s device model, bus frameworks, hardware configuration, synchronization, transfer semantics, Device Tree, error handling, and peripheral-specific register protocols. These concepts provide the foundation for developing reliable, maintainable, and efficient embedded systems using Embedded Linux.
Author: ETDA Trainers
Experience: 10+ Years of Industry Experience in Embedded Systems, IoT, and Embedded C Programming