
Power Management Techniques in RTOS-Based Arduino Projects
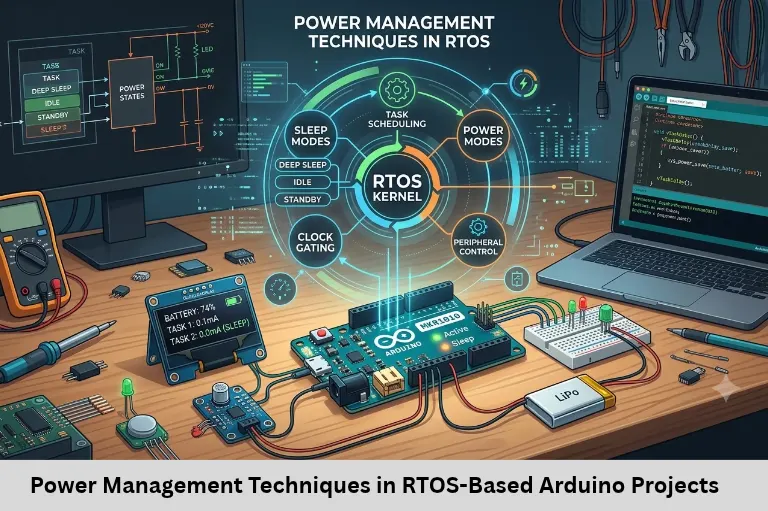
Explore RTOS power management in Arduino using FreeRTOS, tickless idle, sleep modes, interrupts, peripheral control, and low-power techniques. Embedded Tech Development Academy (ETDA).
- Power Management Techniques in RTOS-Based Arduino Projects
-
A Detailed Discussion of Power Management Techniques in RTOS-Based Arduino Projects
- Introduction
- 1. Importance of Power Management in RTOS-Based Systems
- 2. Microcontroller Sleep Modes and Hardware Power Management
- 3. RTOS Power Management Challenges
- 4. Tickless Idle for FreeRTOS Power Management
- 5. Task-Aware Sleep and Peripheral Management
- 6. Dynamic Frequency Scaling and Low-Power Libraries
- 7. Event-Driven Tasks and Interrupt-Based Wake-Up
- 8. Task Coalescing and Sensor Fusion
- 9. Common Power Management Pitfalls
- 10. Practical RTOS Training for Embedded Systems
-
Frequently Asked Questions
- Why is power management important in RTOS-based Arduino projects?
- What is tickless idle in FreeRTOS?
- What is the difference between Idle and Power-Down modes in AVR?
- How can sensors reduce power consumption in Arduino projects?
- How do interrupts help improve power efficiency?
- Can low-power Arduino libraries be used with FreeRTOS?
- Conclusion
A Detailed Discussion of Power Management Techniques in RTOS-Based Arduino Projects
Introduction
Power management is a critical consideration in modern Embedded Systems, particularly in battery-operated devices, wearable electronics, wireless sensor networks, and Internet of Things (IoT) applications. Arduino-based projects using a Real-Time Operating System (RTOS), such as FreeRTOS or RTuinOS, can execute multiple tasks with different timing requirements. However, continuous CPU operation, periodic scheduler interrupts, unnecessary peripheral activity, and frequent sensor polling can increase power consumption and reduce battery life.
Effective power optimization requires coordination between microcontroller hardware and RTOS software. Techniques such as CPU sleep modes, tickless idle operation, peripheral clock management, interrupt-driven execution, dynamic frequency scaling, and event-based task scheduling help reduce energy consumption without compromising system responsiveness. Engineers must also consider wake-up latency, task deadlines, interrupt sources, and sensor operating requirements.
These techniques are valuable in automotive electronics, industrial automation, wearable devices, and Internet of Things (IoT) sensor nodes. Embedded Tech Development Academy (ETDA) introduces learners to practical Embedded Systems concepts, including microcontroller programming and RTOS development. Learners searching for a Top Embedded Training Institute in Bangalore can evaluate hands-on FreeRTOS projects and low-power hardware experiments. The availability and scope of assured placement support can also be considered when selecting a technical training program.
1. Importance of Power Management in RTOS-Based Systems
Why Power Optimization Matters
Power management helps Embedded Systems operate efficiently, especially when battery replacement or charging is difficult.
Important benefits include:
Extended battery life: Essential for wearable electronics and Internet of Things (IoT) sensor nodes.
Thermal management: Reduces heat generation and supports component reliability.
Energy efficiency: Helps satisfy low-power product requirements.
Remote operation: Supports devices deployed in locations with limited power availability.
Power Consumption Components
Microcontroller power consumption depends on CPU activity, clock frequency, peripheral operation, memory access, and external components. Reducing unnecessary switching activity and disabling unused hardware can significantly reduce overall energy consumption.
2. Microcontroller Sleep Modes and Hardware Power Management
Understanding AVR Sleep Modes
Arduino-compatible microcontrollers support different power modes depending on their architecture. For example, the ATmega328P provides several sleep modes.
Idle: CPU execution stops while selected peripherals continue operating.
ADC Noise Reduction: Reduces digital switching activity to support quieter ADC measurements.
Power-Save: Allows asynchronous Timer2 operation under supported configurations.
Power-Down: Stops most internal clock activity while retaining selected wake-up capabilities.
Standby: Allows faster wake-up by keeping the oscillator running.
Peripheral Clock Management
Unused peripherals such as SPI, I²C, UART, and timers can consume power. AVR microcontrollers provide Power Reduction Register (PRR) controls to disable supported peripheral clocks.
Practical Hardware Optimization
In an Internet of Things (IoT) sensor node, disable unused communication interfaces between transmissions. Select sleep modes according to the required wake-up source, timer operation, and response time. Sleep-mode capabilities differ between AVR, ARM Cortex-M, and other microcontroller families.
3. RTOS Power Management Challenges
Scheduler Activity and Periodic Tick Interrupts
An RTOS manages multiple tasks with different priorities and execution periods. A periodic scheduler tick, commonly configured at intervals such as 1 ms, can wake the CPU even when no application task needs execution.
Balancing Sleep and Task Deadlines
The scheduler must determine when the system can safely enter sleep. It must account for blocked tasks, delayed tasks, timer events, interrupt activity, and real-time deadlines. Sleeping too long can delay task execution, while sleeping too briefly provides little energy benefit.
4. Tickless Idle for FreeRTOS Power Management
What Is Tickless Idle?
Tickless idle suppresses unnecessary periodic RTOS tick interrupts when the system has no ready application tasks. The RTOS calculates the expected idle interval and allows the microcontroller to sleep until the next scheduled event or interrupt.
FreeRTOS Implementation
FreeRTOS ports may implement tickless sleep through a platform-specific vPortSuppressTicksAndSleep() function. The implementation depends on the microcontroller, clock source, and RTOS port.
On supported ARM Cortex-M systems, the __WFI() instruction can place the CPU into a wait-for-interrupt state. AVR platforms may use sleep_cpu() with suitable sleep configuration.
Practical Considerations
The sleep implementation must preserve RTOS timekeeping and correctly compensate for suppressed ticks. Engineers should verify timer behaviour, wake-up latency, and interrupt handling before deploying tickless idle in production Embedded Systems.
5. Task-Aware Sleep and Peripheral Management
Checking Task States
Before entering sleep, the RTOS must ensure that no application task is ready to execute. FreeRTOS provides task-state and scheduler-related APIs, but sleep decisions should follow the port’s supported idle and tickless mechanisms.
The idle hook can be used for appropriate low-power operations. Suspending the scheduler manually requires care because interrupts and timing events may still occur.
Sensor and Peripheral Power Control
Sensors and external modules can be disabled between measurements using software shutdown commands, GPIO control, or dedicated load switches. Lazy initialization ensures that hardware is activated only when needed.
For example, an Internet of Things (IoT) temperature-monitoring device can power a sensor before measurement, collect data, transmit the result, and then disable the sensor until its next sampling interval.
6. Dynamic Frequency Scaling and Low-Power Libraries
Dynamic Voltage and Frequency Scaling (DVFS)
Dynamic frequency scaling adjusts processor clock frequency according to workload requirements. Lower frequencies can reduce dynamic power consumption but increase execution time. Voltage scaling, where supported, can provide additional savings.
Arduino platforms do not all provide a standardized DVFS interface. AVR clock prescalers can be configured on supported devices, but changing clock frequency may affect timer calculations, UART baud rates, and RTOS timing.
Low-Power Libraries
Libraries such as LowPower.h for supported AVR boards and Arduino Low Power for compatible SAMD platforms provide convenient sleep interfaces. Architecture compatibility must be checked before using them.
RTOS Integration
Low-power library calls should be coordinated with the RTOS idle mechanism. Avoid placing blocking sleep operations inside ordinary application tasks because they may interfere with scheduling and task deadlines.
7. Event-Driven Tasks and Interrupt-Based Wake-Up
Efficient Task Structure
Continuous polling keeps the CPU active and wastes energy. Event-driven programming allows tasks to block until data or an event becomes available.
FreeRTOS queues, semaphores, and event groups can notify tasks when sensors produce data or external events occur.
Interrupt-Based Wake-Up
External interrupts can wake supported microcontrollers from selected sleep modes. On AVR devices, an external interrupt such as INT0 can act as a wake-up source when the pin configuration and sleep mode permit it.
Example Workflow
A motion sensor generates an interrupt when movement is detected. The interrupt service routine sends a notification to a FreeRTOS task, which reads the sensor and processes the event. The system can return to sleep after completing the required operation.
8. Task Coalescing and Sensor Fusion
Reducing Unnecessary Wake-Ups
Task coalescing combines operations that can be performed during the same active period. For example, sensor acquisition, data processing, and logging can be scheduled together rather than waking the CPU separately for every operation.
Sensor Fusion in Low-Power Systems
Sensor fusion combines measurements from multiple sensors to produce more useful information. In robotics and Internet of Things (IoT) applications, accelerometer and gyroscope readings can be processed together during a scheduled active interval.
This approach can reduce repeated CPU wake-ups, provided sampling accuracy and real-time requirements are maintained.
9. Common Power Management Pitfalls
Mistakes to Avoid
Entering sleep without checking pending RTOS events.
Disabling a peripheral required for a wake-up source.
Using unsupported sleep modes with an RTOS port.
Changing clock frequency without updating timing configurations.
Performing long operations inside interrupt service routines.
Ignoring sensor startup and stabilization time.
Power Optimization Checklist
Measure current consumption in active and sleep states. Verify wake-up sources, task deadlines, timer accuracy, and peripheral shutdown behaviour. Use a power analyzer or suitable current-measurement equipment to compare actual energy consumption before and after optimization.
10. Practical RTOS Training for Embedded Systems
Embedded Tech Development Academy (ETDA) is an option for learners interested in FreeRTOS, Arduino programming, and low-power Embedded Systems development. When evaluating a Top Embedded Training Institute in Bangalore, check for practical exercises involving task scheduling, idle hooks, tickless idle, interrupts, sensor interfacing, and power measurement. Learners should also review the specific terms of the advertised assured placement support.
Frequently Asked Questions
Why is power management important in RTOS-based Arduino projects?
It reduces energy consumption, extends battery life, controls heat generation, and supports reliable operation in battery-powered Embedded Systems and IoT devices.
What is tickless idle in FreeRTOS?
Tickless idle suppresses periodic RTOS tick interrupts during extended idle periods and allows the microcontroller to sleep until the next scheduled event or interrupt.
What is the difference between Idle and Power-Down modes in AVR?
Idle mode stops CPU execution while allowing selected peripherals to operate. Power-Down mode stops most internal clock activity and supports only selected wake-up sources.
How can sensors reduce power consumption in Arduino projects?
Sensors can be disabled between measurements using software shutdown commands, GPIO control, or load switches. Event-driven sampling also reduces unnecessary activity.
How do interrupts help improve power efficiency?
Interrupts allow a microcontroller to remain asleep until an external event occurs, such as a button press or sensor signal, instead of continuously polling for changes.
Can low-power Arduino libraries be used with FreeRTOS?
They can be used on compatible hardware when properly integrated with the RTOS idle and sleep mechanisms. Engineers must verify architecture support, timer behaviour, wake-up sources, and scheduler compatibility.
Conclusion
Power management in RTOS-based Arduino projects requires close coordination between microcontroller hardware, peripheral configuration, and real-time scheduling. Sleep modes, tickless idle, task-aware sleep decisions, peripheral shutdown, dynamic frequency scaling, interrupt-driven execution, and event-based task structures can significantly reduce unnecessary energy consumption.
However, power optimization must not compromise task deadlines, system responsiveness, timer accuracy, or reliable wake-up operation. Engineers should measure actual current consumption, test different sleep configurations, and validate performance under realistic workloads. These techniques are particularly important for battery-powered Embedded Systems, wearable electronics, wireless sensor networks, and Internet of Things (IoT) products.
Embedded Tech Development Academy (ETDA) can be explored by learners seeking practical RTOS and microcontroller training. Those comparing a Top Embedded Training Institute in Bangalore should assess real hardware projects and hands-on debugging experience, while verifying the details of its assured placement support. Strong knowledge of FreeRTOS, Arduino, and low-power design helps engineers develop energy-efficient and reliable embedded products.
Author: ETDA Trainers
Experience: 10+ Years of Industry Experience in Embedded Systems, IoT, and Embedded C Programming