
Linux Process Management for Embedded Systems
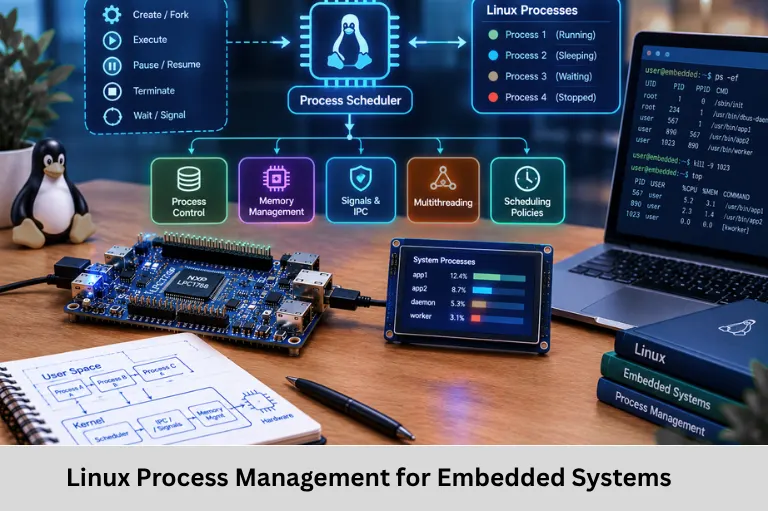
Learn Linux process management, fork(), exec(), process states, scheduling policies, priorities, CPU affinity and real-time concepts for embedded systems. Embedded Tech Development Academy (ETDA).
- Linux Process Management for Embedded Systems
-
Linux Process Management for Embedded Systems
- Introduction to Linux Process Management
- What Is a Process in Embedded Linux?
- Common Processes in Embedded Linux
- How Linux Creates Processes
- exec() and Program Replacement
- Linux Process States
- Linux Scheduler and Embedded Systems
- Real-Time Scheduling Policies
- Per-Process Scheduling Configuration
- Multi-Core Process Management
- Monitoring Linux Processes
- Why Process Management Matters in Embedded Systems
- Frequently Asked Questions
- Conclusion
Linux Process Management for Embedded Systems
Introduction to Linux Process Management
Modern embedded systems are no longer limited to simple microcontrollers executing one infinite loop. Industrial controllers, automotive ECUs, robotics platforms, medical equipment, smart devices, and Internet of Things (IoT) gateways increasingly use Embedded Linux to handle networking, multimedia, sensors, storage, diagnostics, security, and application workloads simultaneously.
At the center of this multitasking capability is Linux process management. A process represents a running program together with its virtual memory, CPU execution context, file descriptors, credentials, and other kernel-managed resources. The Linux kernel creates, schedules, synchronizes, suspends, and terminates processes according to system requirements.
For embedded engineers, understanding process creation, fork(), exec(), process IDs, process states, scheduling policies, priorities, CPU affinity, inter-process communication, and real-time scheduling is essential for designing reliable systems.
Process management becomes particularly important when an embedded device must simultaneously acquire sensor data, control hardware, communicate over Ethernet or CAN, update a display, record diagnostics, and process network packets.
Embedded Tech Development Academy (ETDA) provides practical technical training in Linux, Embedded Linux, programming, microcontrollers, and embedded systems. Learners searching for a Top Embedded Training Institute in Bangalore can develop these Linux and embedded skills through hands-on technical learning with assured placement support.
What Is a Process in Embedded Linux?
Program Versus Process
A program is a passive executable file stored in memory or storage, whereas a process is an active execution instance of that program.
Resources Associated with a Process
A Linux process typically has:
- Process ID (PID)
- Virtual address space
- CPU registers and execution context
- Stack and heap
- Open file descriptors
- Environment variables
- User and group credentials
- Scheduling information
Process Isolation
Linux provides each normal process with its own virtual address space. Therefore, one process normally cannot directly access another process’s memory.
This isolation is valuable in embedded systems because a failure in one application does not automatically corrupt the memory of unrelated applications.
Common Processes in Embedded Linux
Typical Embedded Workloads
An Embedded Linux system may run multiple processes for different system functions.
Examples
Typical processes can handle:
- Sensor data acquisition
- Motor-control supervision
- Network communication
- CAN communication
- User interfaces
- Data logging
- Diagnostics
- Firmware services
- Security monitoring
Multiple Applications Sharing One Kernel
These processes execute independently while sharing kernel services such as CPU scheduling, memory management, device drivers, networking, and file systems.
How Linux Creates Processes
fork() System Call
Linux commonly creates a new process using the fork() system call.
When fork() executes successfully, the kernel creates a child process based on the calling parent process.
Parent and Child Processes
Both processes continue execution after the fork() call, but they receive different return values.
pid_t pid = fork();

if (pid == 0) {
    printf("Child process\n");
} else if (pid > 0) {
    printf("Parent process\n");
}
Process Identification
The child receives its own PID, while the parent can obtain the child’s PID from the return value of fork().
Modern Linux systems use mechanisms such as copy-on-write (COW) so that memory pages do not need to be physically duplicated immediately.
exec() and Program Replacement
Loading a New Program
After fork(), the child commonly uses an exec() family function to replace its current program image with another executable.
Examples include:
execl();
execv();
execlp();
execvp();
Fork and Exec Model
The basic sequence is:
Parent
   |
 fork()
   |
Child
   |
 exec()
   |
New Program
Why fork() and exec() Are Separate
Separating process creation from program loading gives Linux flexibility. The child can modify file descriptors, environment variables, credentials, or other settings before executing the new program.
This model is widely used by shells, service managers, and embedded application launch systems.
Linux Process States
Understanding Process State
A process changes state throughout its lifetime depending on CPU availability, I/O operations, signals, and synchronization events.
Important Process States
Common states include:
- Running: Currently executing on a CPU.
- Runnable: Ready to execute and waiting for CPU scheduling.
- Sleeping: Waiting for an event, I/O operation, timer, or synchronization condition.
- Stopped: Execution has been suspended.
- Zombie: Execution has completed, but the parent has not yet collected the child’s exit status.
Embedded System Behavior
A sensor-monitoring process may remain sleeping until data becomes available. After receiving an event, it becomes runnable and is scheduled by the kernel.
Efficient use of blocking and sleeping mechanisms can reduce unnecessary CPU consumption.
Linux Scheduler and Embedded Systems
Role of the Scheduler
The Linux scheduler determines which runnable task receives CPU execution.
Normal Scheduling
Normal applications traditionally use the Completely Fair Scheduler (CFS), while newer Linux kernel versions use the evolving EEVDF scheduling model for fair-class scheduling. The exact scheduler implementation depends on the kernel version and configuration.
General Embedded Workloads
Fair scheduling is appropriate for workloads such as:
- User interfaces
- Network services
- Logging
- File management
- Background applications
Real-Time Scheduling Policies
SCHED_FIFO
SCHED_FIFO is a real-time scheduling policy.
A higher-priority real-time task can preempt a lower-priority task.
Priority-Based Execution
Linux real-time scheduling priorities commonly range from 1 to 99, with higher numeric values representing higher priority within the real-time scheduling class.
struct sched_param param;
param.sched_priority = 80;
sched_setscheduler(0, SCHED_FIFO, ¶m);Embedded Application
SCHED_FIFO may be used for carefully designed time-critical workloads such as high-priority control processing.
SCHED_RR
SCHED_RR uses real-time priority together with round-robin time allocation among runnable tasks of the same priority.
Suitable Workloads
It can be useful when multiple real-time tasks have the same priority and need to share CPU execution.
Important Limitation
Real-time scheduling does not automatically make an application deterministic. Interrupt latency, kernel configuration, memory allocation, device drivers, synchronization, and system load can all affect timing.
Per-Process Scheduling Configuration
sched_setscheduler()
Linux allows scheduling attributes to be configured for individual processes.
sched_setscheduler(pid, SCHED_FIFO, ¶m);sched_setparam()
The sched_setparam() system call changes scheduling parameters such as real-time priority.
Priority Design
For an embedded application, engineers should assign priorities according to timing requirements rather than simply assigning the highest priority to the most important-looking process.
Priority Inversion
Poor synchronization design can create priority inversion, where a high-priority task is indirectly delayed by a lower-priority task holding a required resource. Priority-inheritance mechanisms can help address this problem in appropriate synchronization designs.
Multi-Core Process Management
Processes on Multiple CPU Cores
Modern embedded processors commonly contain multiple CPU cores. Linux can schedule runnable processes across available CPUs.
CPU Affinity
CPU affinity allows a process or thread to be restricted to selected CPUs.
For example:
CPU 0 → Control processing
CPU 1 → Networking
CPU 2 → Graphics
CPU 3 → Logging
Why Affinity Matters
CPU affinity can improve cache locality and reduce interference between workloads. In time-sensitive embedded systems, carefully designed CPU isolation and affinity strategies can also improve timing predictability.
Monitoring Linux Processes
ps Command
The ps command displays process information:
ps auxtop Command
The top command provides continuously updated information about CPU and memory usage.
topProcess Inspection
Engineers can inspect:
- PID
- CPU utilization
- Memory usage
- Process state
- User ownership
- Runtime information
Embedded Debugging
These tools are useful when diagnosing CPU overload, memory consumption, blocked processes, unexpected process termination, or excessive background activity.
Why Process Management Matters in Embedded Systems
Reliability and Performance
Poor process management can cause:
- Missed timing requirements
- CPU starvation
- Increased scheduling latency
- Unstable control behavior
- Network packet delays
- Audio/video glitches
- Excessive CPU utilization
Deterministic System Design
Engineers must consider process priorities, blocking behavior, synchronization, CPU affinity, I/O latency, and scheduling policies together.
Linux Versus Traditional RTOS Design
Linux provides extensive networking, storage, security, drivers, and application frameworks while also supporting real-time scheduling capabilities. However, a general-purpose Linux configuration should not automatically be assumed to provide hard real-time guarantees.
Frequently Asked Questions
What is process management in Linux?
Process management is the kernel-controlled mechanism for creating, scheduling, executing, synchronizing, and terminating processes.
What is the difference between a program and a process?
A program is an executable or code stored on a system, while a process is an active execution instance of that program with its own runtime state and resources.
What does fork() do in Linux?
fork() creates a new child process from an existing parent process. The child receives its own process identity and continues execution from the point of the fork() call.
What is the purpose of SCHED_FIFO?
SCHED_FIFO provides a real-time scheduling policy in which runnable tasks are ordered primarily according to their real-time priority and FIFO behavior at equal priority.
Why is CPU affinity useful in embedded Linux?
CPU affinity can restrict a process or thread to selected processor cores, helping engineers manage CPU utilization, cache locality, workload isolation, and timing behavior.
Conclusion
Linux process management is a fundamental part of Embedded Linux development because modern embedded systems must execute multiple workloads concurrently while maintaining predictable performance and reliable resource utilization. Understanding the complete process lifecycle—from fork() and exec() to scheduling, blocking, waking, synchronization, and termination—helps engineers design more robust applications.
Knowledge of process IDs, virtual memory, process states, scheduling classes, SCHED_FIFO, SCHED_RR, priorities, CPU affinity, system calls, process monitoring, and real-time constraints is especially important for engineers developing industrial controllers, robotics systems, automotive platforms, medical equipment, and IoT gateways.
Real-time scheduling should be applied carefully. A high-priority process does not automatically guarantee deterministic behavior. Engineers must also analyze interrupt latency, driver behavior, synchronization, memory management, CPU utilization, I/O delays, and priority inversion when designing time-sensitive applications.
Embedded Tech Development Academy (ETDA) provides practical technical training covering Linux, Embedded Linux, C/C++, operating systems, microcontrollers, communication protocols, and embedded systems development. Learners looking for a Top Embedded Training Institute in Bangalore can strengthen their process-management and Linux skills through hands-on technical learning with assured placement support.
For engineers working on embedded systems, process management connects operating-system concepts with real hardware requirements. Understanding how a Linux kernel schedules processes, manages CPU resources, and handles application execution provides a strong foundation for developing reliable embedded software.
Embedded Tech Development Academy (ETDA) helps learners build these practical skills through industry-oriented technical training, while a Top Embedded Training Institute in Bangalore approach can combine Linux concepts with real embedded development and assured placement support.
As Embedded Linux continues to power automotive ECUs, robotics, industrial automation, edge computing, networking devices, and Internet of Things (IoT) platforms, process management remains a critical engineering skill. Strong knowledge of scheduling, process states, CPU affinity, system calls, and real-time behavior enables developers to make better architectural decisions and build efficient embedded systems. Embedded Tech Development Academy (ETDA) supports this technical learning journey with practical training and assured placement support for learners seeking industry-oriented skills at a Top Embedded Training Institute in Bangalore.
Author: ETDA Trainers
Experience: 10+ Years of Industry Experience in Embedded Systems, IoT, and Embedded C Programming